All Projects
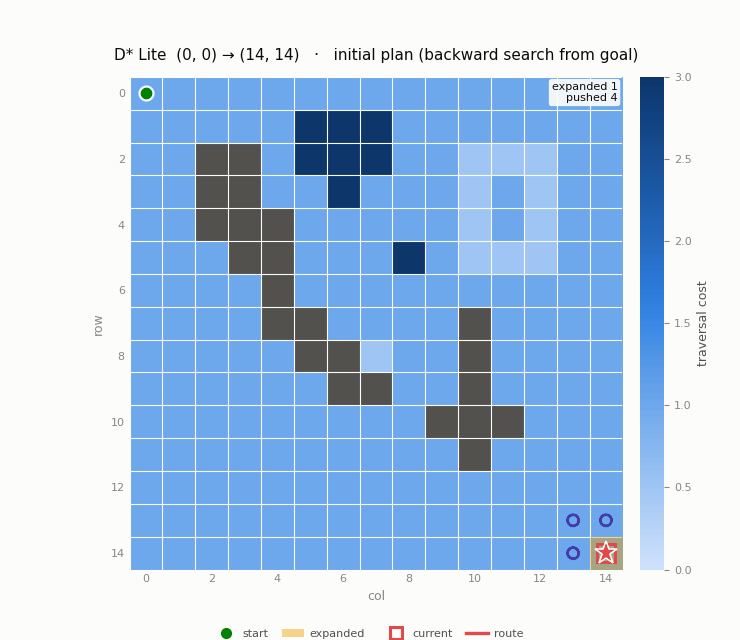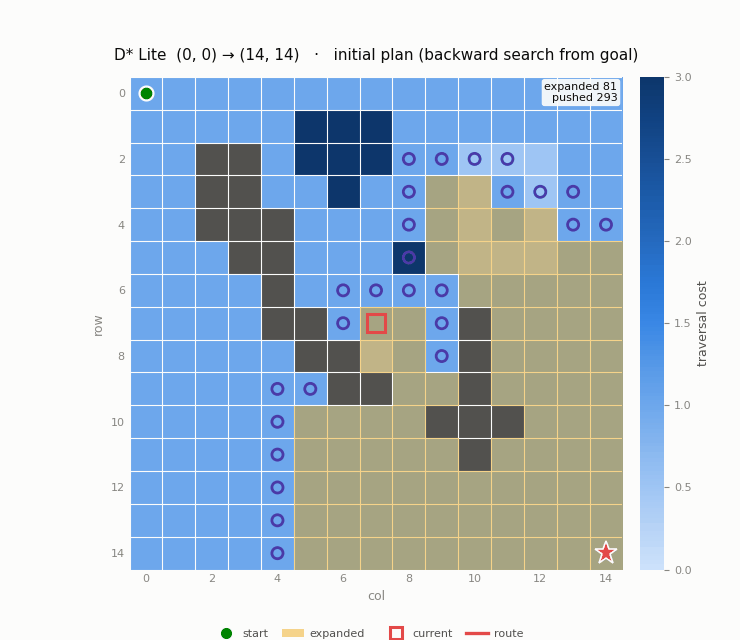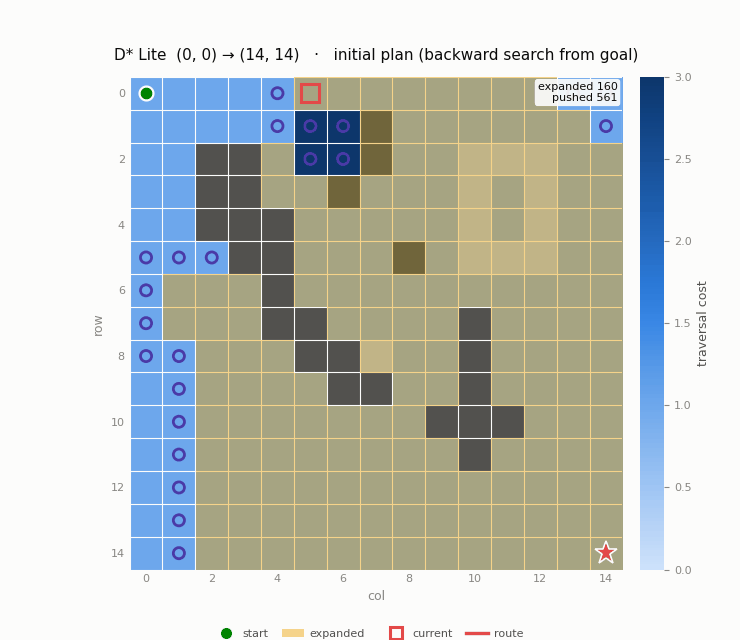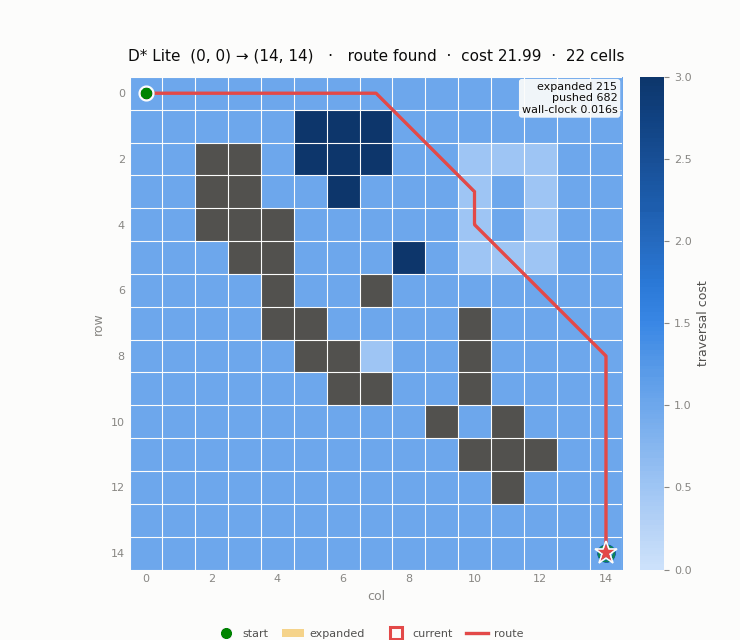
Incremental Path Replanning for Robot Navigation: A D* Lite Implementation and Benchmark
Built A* and D* Lite from scratch with custom priority queues, benchmarking them across 8 terrains and 4 scenarios to demonstrate a 35–42% reduction in node evaluations for incremental replanning (alongside wall-clock trade-off analysis). Extended the planner to a 2–3 robot multi-agent system using CBS-style constraints.
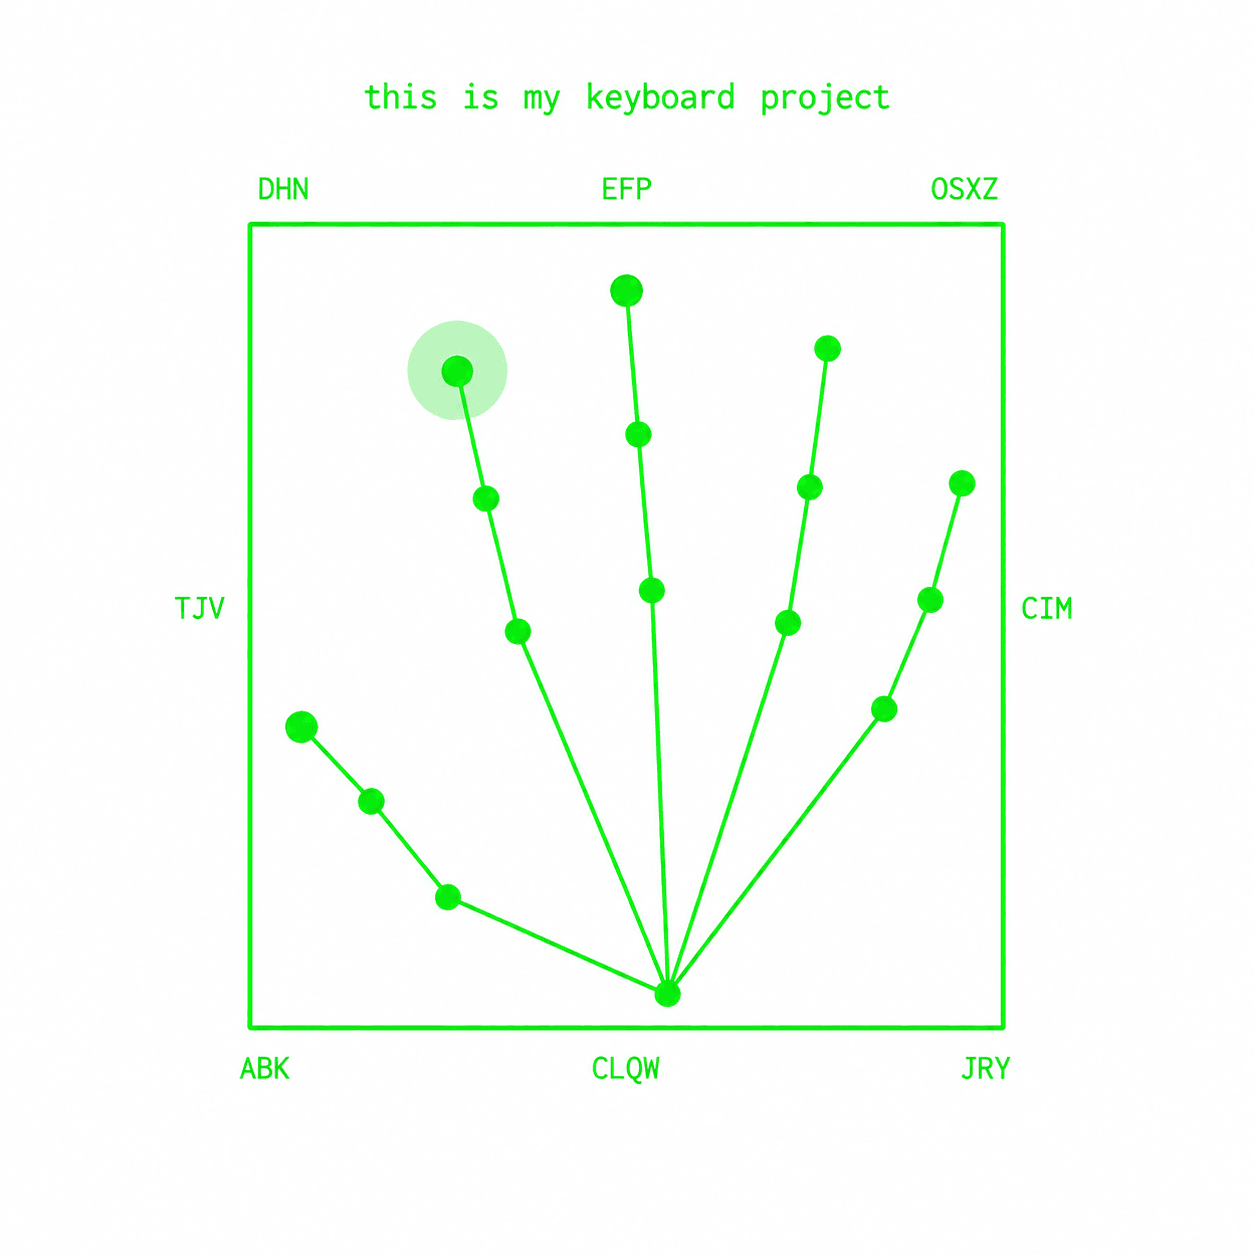
Invisible Keyboard for Assistive Accessibility
An AI-powered, touch-free gesture input system that utilizes Hidden Markov Models and Viterbi decoding to provide an intuitive alternative to traditional physical keyboards.
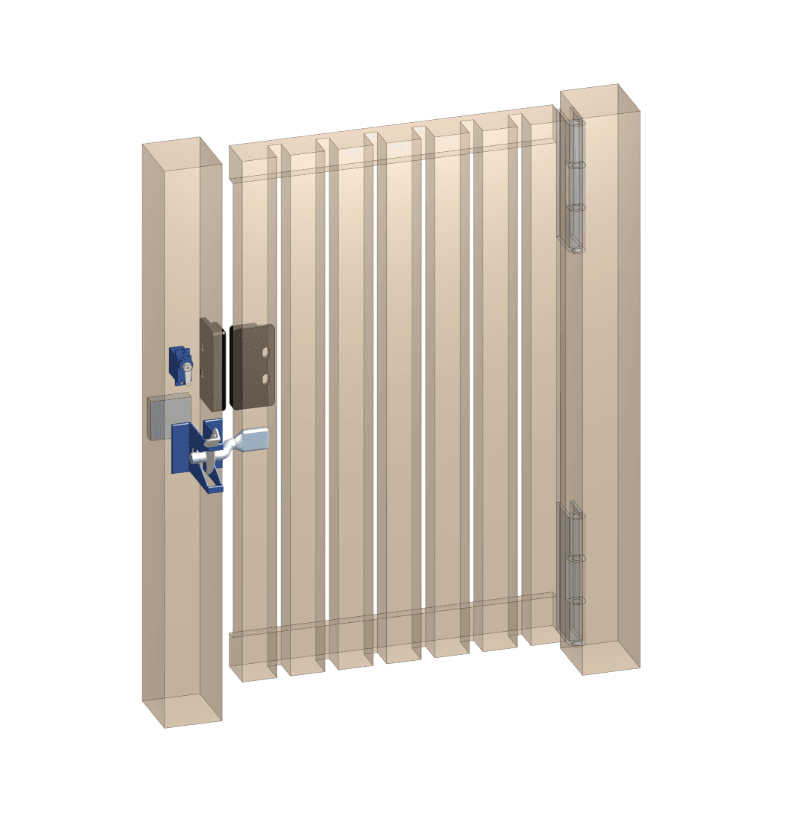
Child Safety Gate System: Multi-Stakeholder Hardware Design for Friends Daycare
Framed and co-designed a battery-powered staff wristband and servo-actuated gate system for a GTA daycare, applying stakeholder prioritization, steelmanning, and Pugh chart analysis to deliver a justified, evidence-backed solution that reduced staff supervision workload while maintaining child containment and independent parent access.
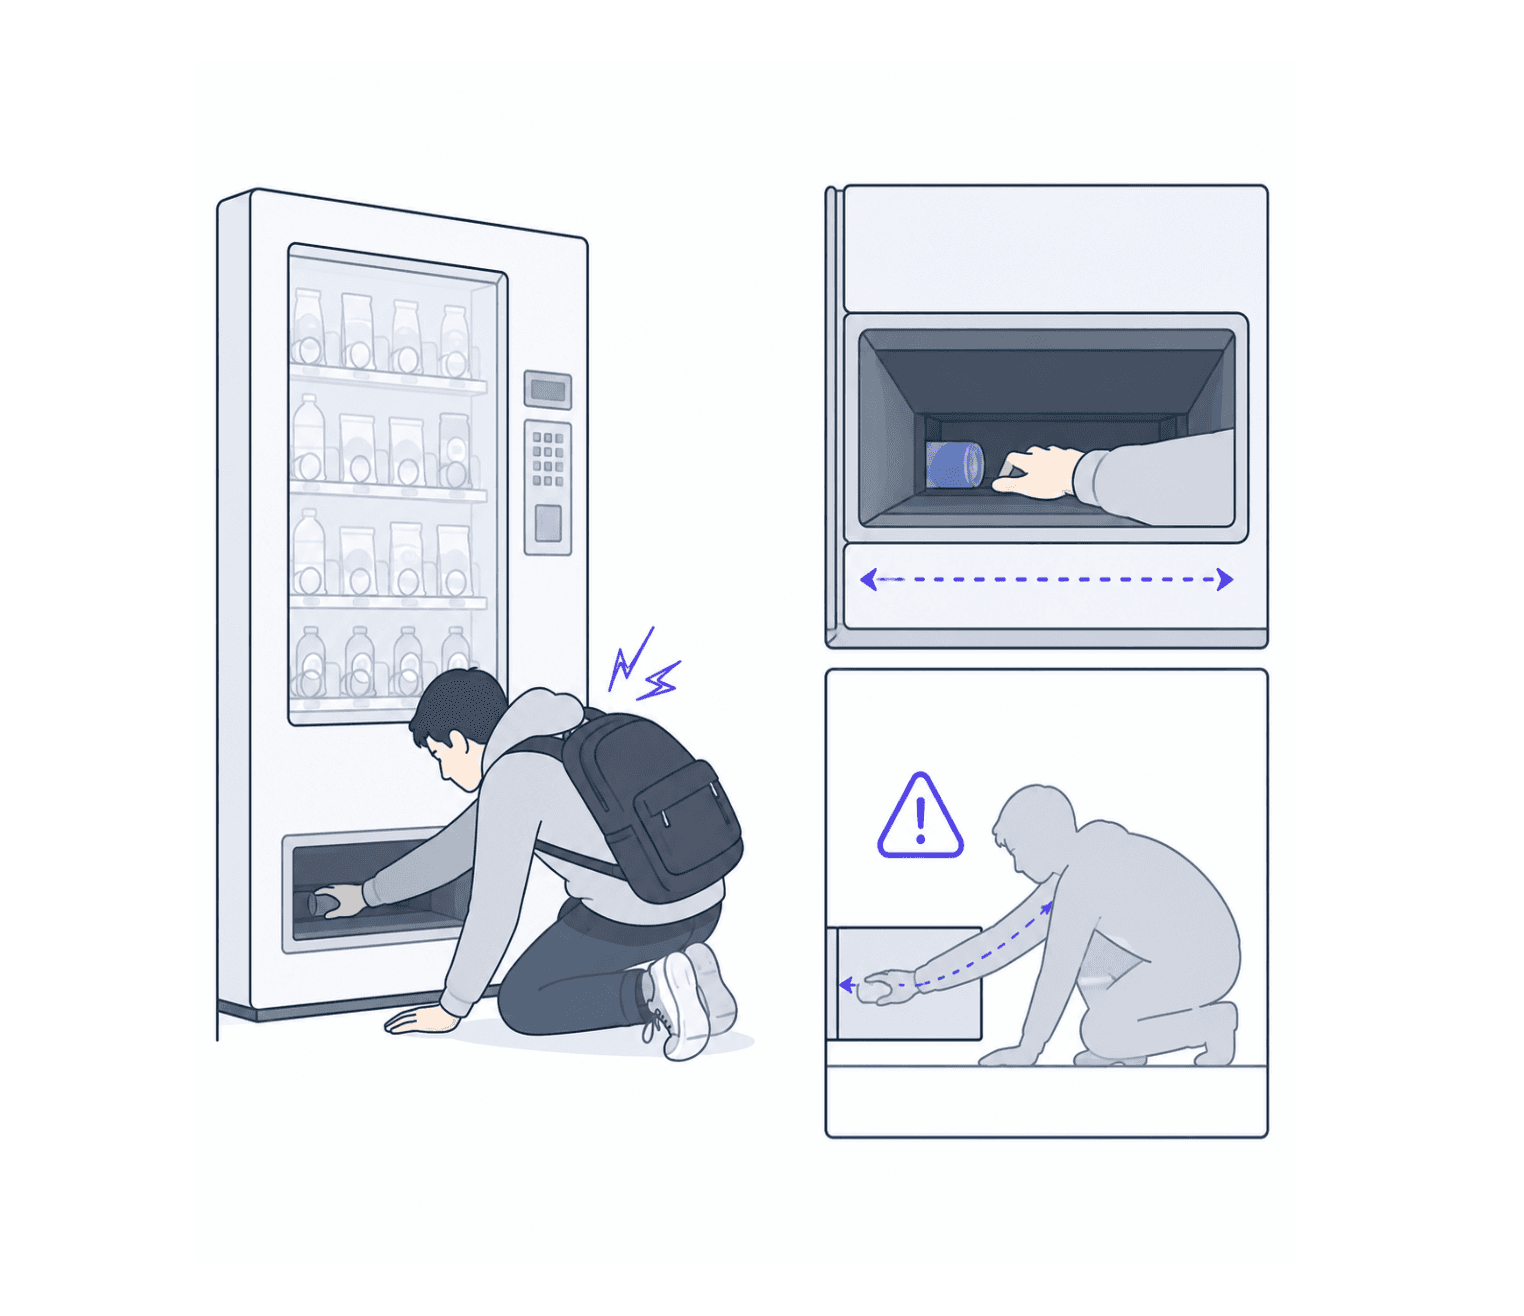
Ergonomic Vending Machine Redesign: Human-Centered Accessibility Engineering
Led the wrist ergonomics validation for a team of five that redesigned a campus vending machine retrieval interface, replacing a biased claw-based concept with an evidence-backed one-way gravity flap, cutting measured wrist deviation and improving retrieval accessibility for 300+ daily users.
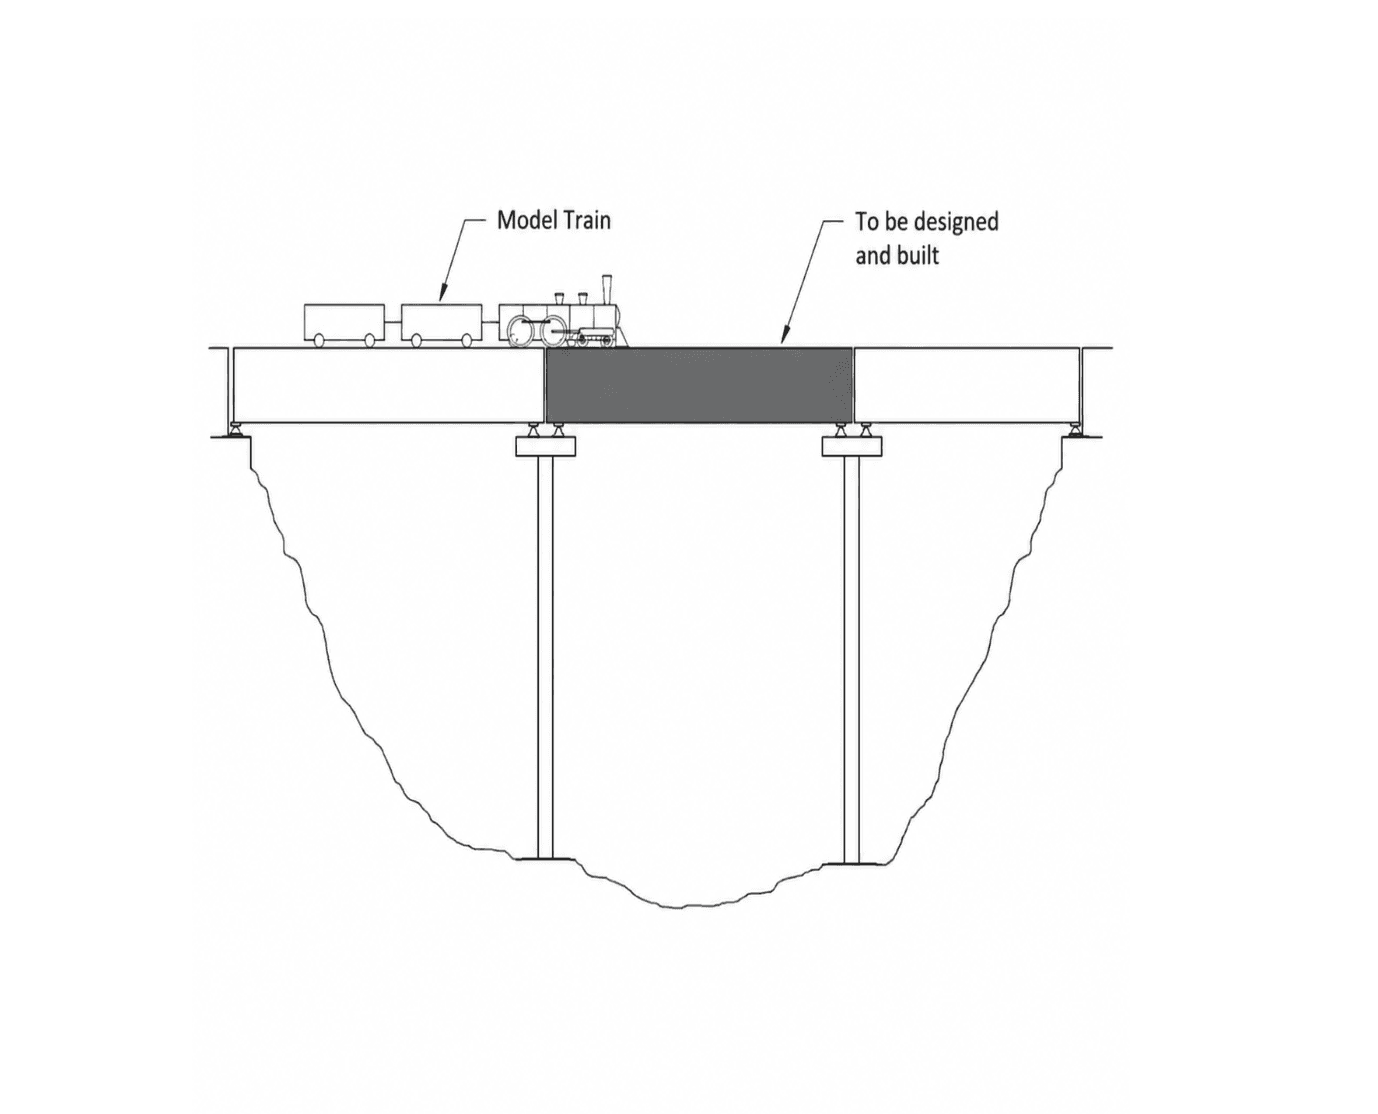
Matboard Beam Bridge: MATLAB Structural Simulation and Failure Analysis
Co-wrote a MATLAB simulation that modeled bending moment and shear force envelopes across a 1200 mm span, driving iterative cross-section optimization that improved the bridge factor of safety from 0.84 to 2.38. Then, I analyzed the gap between the 1092 N theoretical prediction and 133 N physical failure to uncover real-world splice failure modes.